In today's metalworking and automotive landscape, acquiring a robotic cell (MIG/MAG, TIG or Laser) is often perceived as the "holy grail" of productivity. However, field data tell a different story. Without prior methods engineering work, there is frequently a disconnect between installed capacity and actual performance.
The premise is harsh but necessary: automating an inefficient process only magnifies the inefficiency. This technical article breaks down the architecture of time in robotic environments and shows how methods engineering is the only vector capable of unlocking the real ROI of automation.
The automation paradox: Why the robot is not enough
The myth of linear productivity in industrial investment
There is a mistaken belief that replacing a manual welder with a robotic arm guarantees a proportional and linear increase in output. Operational reality shows that the robot, although tireless and precise, is a slave to its environment. If the supply logistics, the fixture design or the filler-metal strategy fail, the fastest machine in the world will generate more costly wait times.
Identifying the 70% of hidden inefficiencies in the process periphery
Our audits reveal an alarming figure: 70% of the inefficiencies in a welding cell do not come from the robot's kinematics, but from the periphery. These inefficiencies reside in fixture feeding, loading ergonomics, part evacuation and unrecorded micro-stops. The robot is not the bottleneck; the bottleneck is the peripheral system's inability to keep pace with the machine.
Methods engineering vs. robotic programming: Where is the bottleneck?
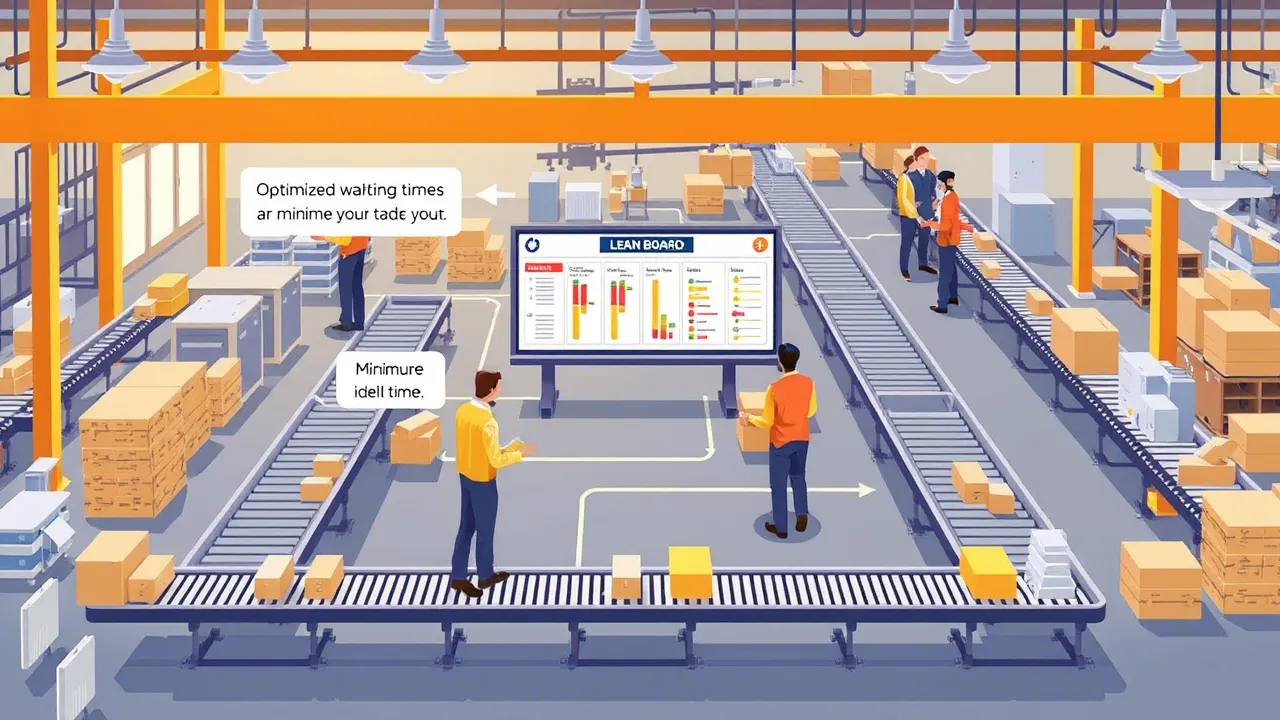
While the programmer focuses on motion interpolation and amperage, the methods engineer must focus on the flow. The conflict arises when the robot code is optimized to gain 0,5 seconds on a path, but the 12 seconds of dead time (idle time) caused by an operator who has to walk three steps to pick up a component are ignored. The battle for productivity is won in the design of the human work method, not only on the Teach Pendant.
Technical analysis of Cycle Time in welding cells
Breaking down the time structure: Technological (Tt) vs. Manual (Tm)
Traditional "stopwatch" time study is obsolete in this environment. Strict segregation is required:
- Technological Time ($T_t$): Composed of the Arc-on time (effective arc-on time) plus air time (no-load movements of the TCP - Tool Center Point).
- Manual Time ($Tm$): Includes loading components into the fixture, actuating clamps (pneumatic or manual), unloading, visual inspection and torch cleaning.
The productivity equation depends on minimizing the gap where the robot waits for the human ($T_m > T_t$) or the human waits for the robot ($T_t > T_m$).
The reality of Arc-on time in the Spanish metalworking industry
In today's industrial fabric, particularly in metalworking SMEs, the average Arc-on time rarely exceeds 45% of total available time without deep methods intervention. The rest is air time, loading/unloading time and minor stops. Raising this ratio does not depend on buying a faster robot, but on densifying the welding operations and optimizing external loading (rotary tables or double stations).
Limitations of stopwatch time study in robotic environments
The stopwatch does not discriminate between a stop for nozzle cleaning (necessary) and a stop due to lack of material (avoidable). At Cronometras, we advocate integrated measurement that correlates the PLC log with analyst observation in order to segregate value-added times from pure interference times.
OEE in welding: Real measurement of Overall Equipment Effectiveness
Availability: The impact of micro-stops (wire changes and cleaning)
Availability is usually overestimated. "Invisible" items such as the spatter cleaning cycle at the cleaning station (cleaning station), wire coil changes or jams in the liner constitute a constant erosion of OEE. A 30-second micro-stop every 10 cycles represents a massive loss of accumulated availability that is often not tabulated in standard MES systems.
Performance and speed: Differences between theoretical and actual cm/min
The welding speed parameter (cm/min) on the data sheet is theoretical. In production, the actual speed is frequently reduced by operators or supervisors to compensate for deviations in part quality or in the joint gap. This speed reduction is a symptom of a failure in the prior forming process, directly impacting the Performance indicator of the OEE.
Quality and rework: When manual finishing destroys the robot's profitability
If a robotic process requires systematic subsequent manual touch-up exceeding 2%, the cell has technically failed. The cost of the "touch-up operator" destroys the robot's savings. Quality must be guaranteed through fixture repeatability and torch maintenance, not through corrective post-mortem labor.
Man-Machine Synchronization: Optimization tools
Applying MTM-UAS and MOST to predict loading and unloading times
The stopwatch is reactive; predetermined time systems (such as MTM-UAS) are predictive. Before installing the cell, we must know exactly how much standard time the fixture loading requires.
- Practical case: If MTM dictates 40s of manual loading and the robot cycle is 20s, the cell will be idle 50% of the time unless a double station is implemented or the workload is rebalanced.
The Man-Machine Chart and optimal operator saturation (85-90%)
The technical goal is to achieve operator saturation between 85% and 90%, considering the ILO rest coefficients. An unbalanced Man-Machine Chart is a capital leak. If the operator has 40% saturation, we are paying for "active waiting".
"Hidden Time" strategies: Value-added operations during the automatic cycle
The key lies in "Hidden Time". While the Technological Time ($T_t$) is running, the operator must perform operations that add value: deburring, palletizing, dimensional inspection or preparation of the next kit (kitting). Turning waiting time into production time is the essence of modern methods engineering.
2025 regulations: Ergonomics, safety and fatigue according to the ILO
UNE-EN ISO 11228: Impact of manual handling of loads on standard time
By 2025, regulations on manual handling of loads are becoming stricter. When calculating standard time, it is imperative to apply recovery coefficients if the workstation design forces awkward postures or high frequencies. Ignoring fatigue in the feeding of high-cycle cells increases micro-absenteeism and reduces overall OEE by up to 15% annually through degradation of the human pace.
Rest and recovery allowances in cell feeding
There is no such thing as a "robot operator". Time engineering must integrate the allowances for physical and mental fatigue (sustained attention) dictated by the ILO. A capacity calculation that assumes a constant 100% pace over 8 hours is a technical fiction that leads to failed production planning.
Safety in Cobots (ISO/TS 15066): The challenge of variable cycle times
The integration of collaborative robots (Cobots) introduces a complex variable: adaptive speed. According to ISO/TS 15066, the robot must reduce its speed in response to human proximity. This means that Cycle Time ($T_c$) is no longer a constant, but a variable dependent on the operator's position. Dynamic studies (simulation or MOST) are required to define a legal and realistic standard time.
Process route audit and the "Digital Twin"
TCP path optimization and air time reduction
A code audit can reveal critical opportunities. Reducing the torch approach distance (from 50mm to 10mm safe) and optimizing the robot wrist reorientation to minimize air time can reduce by between 12% and 18% on parts with multiple short beads.
From the stopwatch to PLC telemetry: New measurement standards 4.0
Measurement is evolving toward data extraction. Time study must be validated with PLC telemetry to identify micro-deviations invisible to the human eye. Industry 4.0 demands that "standard time" be a living data point, fed by the process Digital Twin.
The importance of fixture repeatability in technical productivity
Technical productivity in welding depends 60% on the quality and repeatability of the fixture and only 40% on the robot. A poorly designed fixture that requires manual adjustments by the operator on every cycle invalidates any attempt at time standardization.
Conclusions: Toward an audit of kinematic and human synchronization
Efficiency in robotic welding cannot be purchased "turnkey"; it is built through methods engineering. At Cronometras, we conclude that for the 2025 horizon, the role of the time analyst must transform into that of a Kinematic and Human Synchronization Auditor.
It is imperative to combine the precision of MTM to validate the workstation design, the rigor of ILO regulations to ensure human sustainability, and the robot's data analytics to optimize the process route. Only by mastering this triad can an investment in capital be transformed into a real competitive advantage.
Don't want to do it yourself? We do it for you from €800
If you prefer to outsource it, Cronometras delivers a complete time and motion study from a single video: elemental breakdown, OIT/TAL fatigue allowances, standard time with tolerances, and a report in PDF + Excel + JSON ready to present to management.